An Adaptive Local Trajectory Planning Method for DWA Based on the ACT-R Cognitive Mechanism
Keywords:
Dynamic Window Approach (DWA), ACT-R Cognitive Mechanisms, Local Path Planning, Unmanned Ground VehicleAbstract
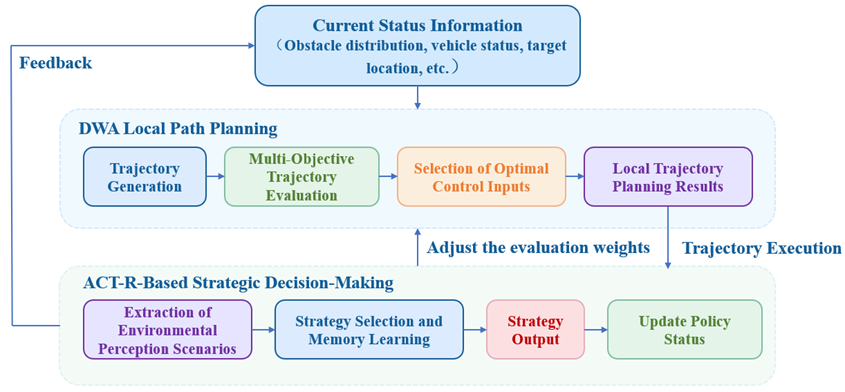
To address the issues of fixed evaluation weights and the lack of historical experience utilization in the traditional Dynamic Window Approach (DWA) for autonomous vehicles in complex dynamic environments, this paper proposes an adaptive local trajectory planning method based on the ACT-R cognitive mechanism. First, the system constructs an environmental perception based on obstacle clearance, predicted risks from dynamic obstacles, and target progress, and establishes three cognitive planning strategies: Normal, Avoid, and Recover. Second, the memory activation mechanism of ACT-R is utilized to describe the historical usage characteristics of different strategies, and utility feedback learning is employed to reflect the long-term effectiveness of strategies under different environmental states. This allows the results of strategic decisions to be mapped in real time to the multi-objective evaluation function of DWA, thereby achieving adaptive and dynamic adjustment of planning weights. Finally, simulation results show that in mixed static and dynamic obstacle scenarios, while ensuring 100% collision-free arrival, this method achieves an average speed 30.17% higher than traditional DWA, reduces travel time by 18.48%, and improves trajectory smoothness by 46.34%, effectively balancing safety and travel efficiency.
References
Han, Y., Liu, Y., Guan, T., Lan, L., & Tang, N. (2025). Improved A* and dynamic window approach for unmanned vehicle path planning. Journal of Shandong University (Engineering Science Edition), 55(3), 16-24. DOI:10.6040/j.issn.1672-3961.0.2024.023
Zhu, M., Hu, F., Li, N., Zhu, S., & Wu, Q. (2023). Summary of path planning algorithms for driverless vehicle. Agricultural Equipment & Vehicle Engineering, 61(11), 18-22. DOI:10.3969/j.issn.1673-3142.2023.11.004
Zhang, R., Zhou, L., & Liu, Z. (2024). Dynamic path planning for mobile robot based on RRT* and dynamic window approach. Journal of System Simulation, 36(4), 957-968. DOI: 10.16182/j.issn1004731x.joss.22-1543
Zhao, L., Li, C., Zhang, W., Chen, D., & Li, Z. (2024). Optimization of robot static dynamic local path planning method based on integrating attraction-repulsion and dynamic window approach. Information and Control, 53(2), 226-237. DOI: 10.13976/j.cnki.xk.2023.2578
Wang, X., Qi, Z., Yang, Z., Wang, D., Huang, H., & Lu, M. (2025). Local path planning for agricultural robots based on DAV_DWA. Transactions of the Chinese Society for Agricultural Machinery, 56(2), 105-114.
Xu, W., Zhang, Y., Yu, L., Zhang, T., & Cheng, Z. (2023). A local path planning algorithm based on improved dynamic window approach. Journal of Intelligent & Fuzzy Systems, 45(3), 4917-4933.
Gong, X., Gao, Y., Wang, F., Zhu, D., Zhao, W., Wang, F., & Liu, Y. (2024). A local path planning algorithm for robots based on improved DWA. Electronics, 13(15), 2965.
Liu, A., Liu, C., Li, L., Wang, R., & Lu, Z. (2025). An improved fuzzy-controlled local path planning algorithm based on dynamic window approach. Journal of Field Robotics, 42(2), 430-454. DOI: 10.1002/rob.22419
Hossain, T., Habibullah, H., Islam, R., & Padilla, R. V. (2022). Local path planning for autonomous mobile robots by integrating modified dynamic-window approach and improved follow the gap method. Journal of Field Robotics, 39, 371-386.
Kobayashi, M., & Motoi, N. (2022). Local path planning: Dynamic window approach with virtual manipulators considering dynamic obstacles. IEEE Access, 10, 17018-17029.
Yang, Z., Li, N., Zhang, Y., & Li, J. (2023). Mobile robot path planning based on improved particle swarm optimization and improved dynamic window approach. Journal of Robotics, 2023, Article ID 6619841, 1-16.
Sarkis, S. S., Elfayoumi, O. S., Jaradat, M. A., & Emran, B. J. (2025). Adaptive dynamic window approach for mobile robot motion control using particle swarm optimization. IEEE Access, 13, 212104-212120. DOI: 10.1109/ACCESS.2025.3624130
Cina, M., & Rad, A. B. (2023). Categorized review of drive simulators and driver behavior analysis focusing on ACT-R architecture in autonomous vehicles. Sustainable Energy Technologies and Assessments, 56, 103044.
Oh, H., Yun, Y., & Myung, R. (2024). Driver behavior and mental workload for takeover safety in automated driving: ACT-R prediction modeling approach. Traffic Injury Prevention, 25(3), 381-389.
van der Velde, M., Sense, F., Borst, J. P., & van Maanen, L. (2022). Capturing dynamic performance in a cognitive model: Estimating ACT-R memory parameters with the linear ballistic accumulator. Topics in Cognitive Science, 14(4), 889-903.
Yang, Y. C., & Stocco, A. (2024). Allocating mental effort in cognitive tasks: A model of motivation in the ACT-R cognitive architecture. Topics in Cognitive Science, 16(1), 74-91.
Fisher, C. R., Houpt, J., Larue, O., & Schmidt, K. (2025). Using systems factorial technology for global model analysis of ACT-R's core architectural assumptions. Journal of Mathematical Psychology, 125, 102924.