Obstacle Avoidance Path Planning for Robotic Arm Based on Improved RRT Algorithm
Keywords:
RRT* Algorithm, RRT Algorithm, Obstacle Avoidance Path Planning, Six-axis Robotic Arm, Sampling Optimization, B-spline CurveAbstract
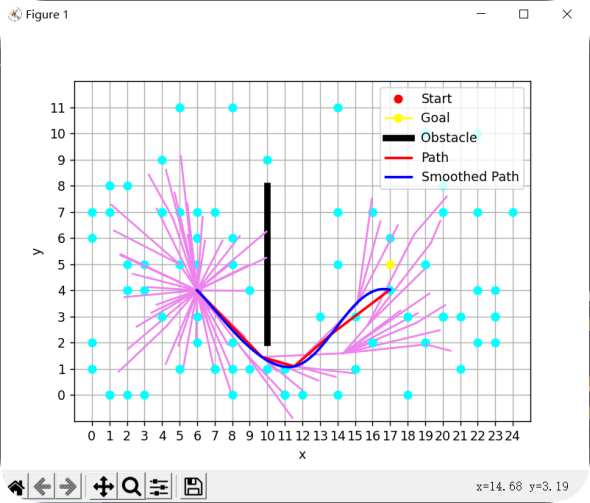
The Rapidly-exploring Random Tree (RRT) algorithm and its variant, RRT*, are commonly used for robotic arm path planning but suffer from high randomness, non-optimal paths, and low efficiency. To address these issues, this paper proposes an improved RRT* algorithm that incorporates a goal-biased sampling strategy and cubic B-spline curve fitting. The method defines and dynamically restricts the search area during tree expansion to improve planning efficiency and goal orientation. Subsequently, cubic B-spline fitting is applied to smooth the path and reduce redundant nodes. Simulation experiments conducted in Python demonstrate that compared to traditional RRT and RRT* algorithms, the proposed approach generates shorter paths with fewer nodes and higher planning success rates, validating its effectiveness for robotic arm obstacle avoidance path planning.
References
Kaya, O., & Tingelstad, L. (2024, July). Comparison of RRT, APF, and PSO-Based RRT-APF (PS-RRT-APF) for collision-free trajectory planning in robotic welding. In 2024 10th International Conference on Control, Decision and Information Technologies (CoDIT) (pp. 2639-2644). IEEE.
Liu, Y., & Zuo, G. (2020, August). Improved RRT path planning algorithm for humanoid robotic arm. In 2020 Chinese Control And Decision Conference (CCDC) (pp. 397-402). IEEE.
Liang, J., Luo, W., & Qin, Y. (2024). Path Planning of Multi-Axis Robotic Arm Based on Improved RRT∗. Computers, Materials & Continua, 81(1).
Yao, F. E. N. G., Zhifeng, Z. H. O. U., & Yichun, S. H. E. N. (2023). Obstacle avoidance path planning based on improved RRT algorithm. Chinese J. Eng. Design, 30(06), 707-716.
JIANG, Q. L., & XU, J. (2025). Application of Improved PSO-PH-RRT* Algorithm in Intelligent Vehicle Path Planning. Journal of Northeastern University (Natural Science), 46(3), 12.
Haoduo, J. I. A., Lijin, F. A. N. G., & Huaizhen, W. A. N. G. (2025). Adaptive path planning of manipulators combining Informed-RRT* with artificial potential field. Computer Integrated Manufacturing System, 31(4), 1179.
SUN, Z., CHENG, J., BI, Y., ZHANG, X., & SUN, Z. (2025). Robot path planning based on a two-stage DE algorithm and applications. Journal of Southeast University (English Edition), 41(2).
Zhang, Y., & Chen, P. (2023). Path planning of a mobile robot for a dynamic indoor environment based on an SAC-LSTM algorithm. Sensors, 23(24), 9802.
Xia, X., Li, T., Sang, S., Cheng, Y., Ma, H., Zhang, Q., & Yang, K. (2023). Path planning for obstacle avoidance of robot arm based on improved potential field method. Sensors, 23(7), 3754.
Downloads
Published
Issue
Section
License
Copyright (c) 2026 Zhicheng Wang, Xiaoying He, Jialing Tang, Jianhang Zhang

This work is licensed under a Creative Commons Attribution 4.0 International License.