Design of an Intelligent Tea-Picking Robot Based on STM32 and Machine Vision
Keywords:
STM32, machine vision, YOLOv8, intelligent tea-picking robot, host computerAbstract
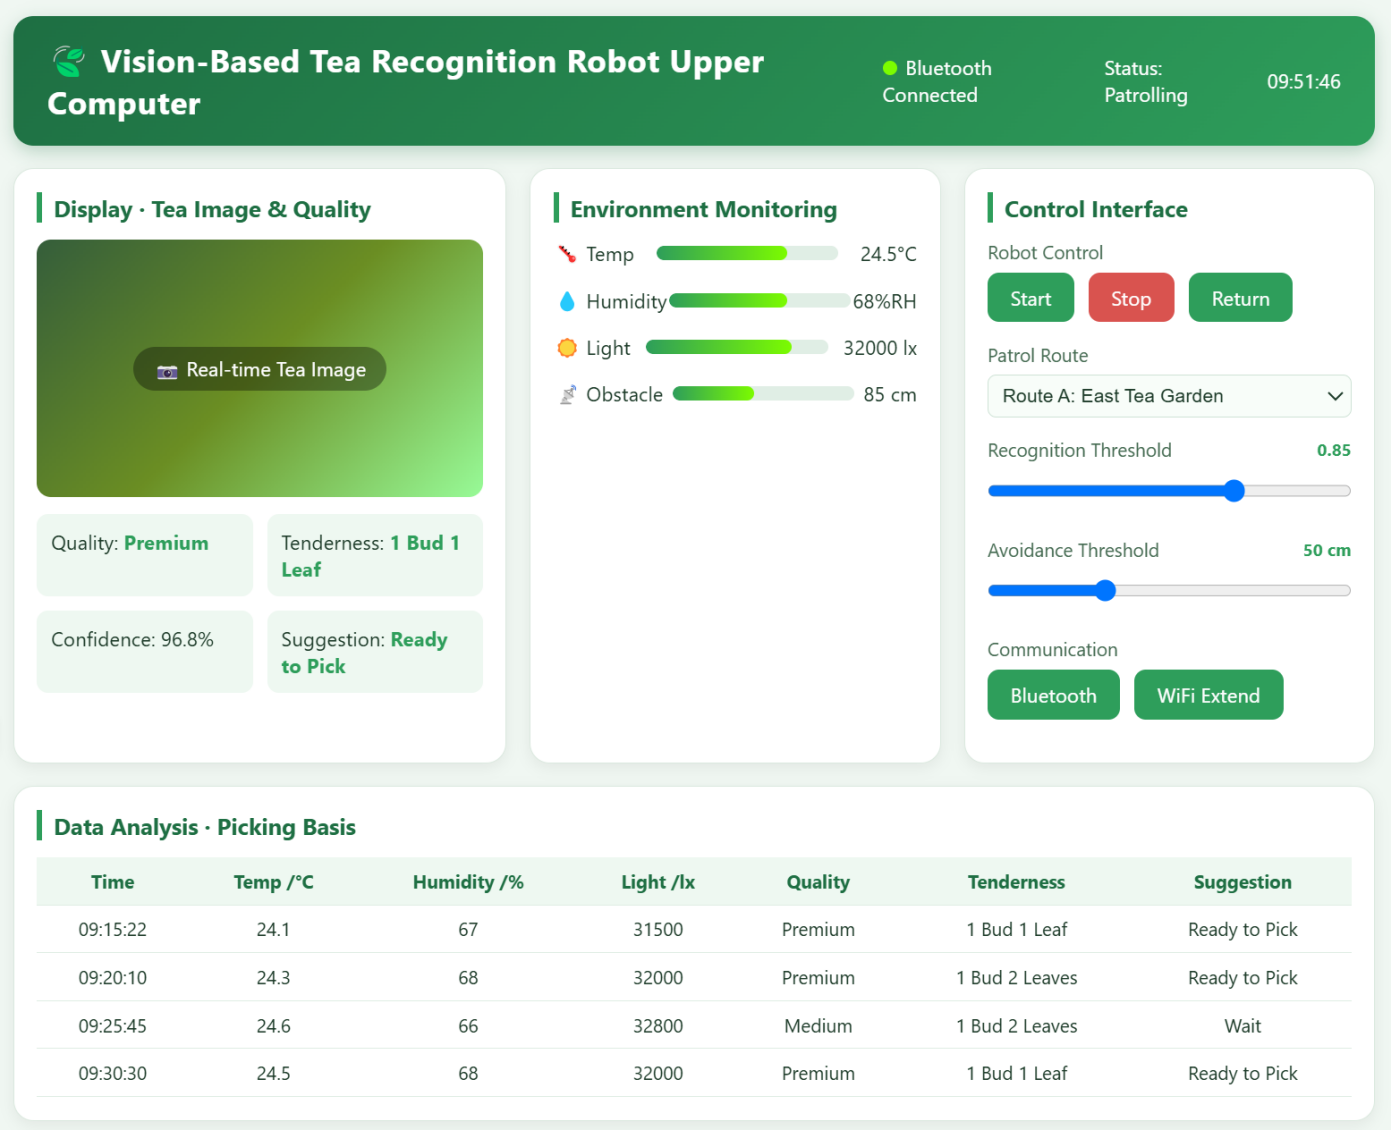
To improve the recognition rate of high-quality tea shoots and picking efficiency while reducing labor costs, this study develops an intelligent tea-picking robot for a tea plantation in Wuyishan, China. Based on the operational requirements of the plantation, the main functional modules of the robot are identified and its overall system layout is established. After completing the mechanical design and three-dimensional modeling, the STM32 is selected as the main controller. Hardware components are selected and circuit designs are developed for the machine-vision module, robotic-arm picking module, and infrared sensing module. The basic system functions are then implemented through software programming. Finally, YOLOv8 is used to train a dataset for tea-shoot quality recognition and to evaluate system performance. The test results indicate that the recognition performance generally meets the design requirements. This work provides a foundation for the subsequent automatic picking of high-quality tea shoots by the robot.
References
[1]You, W. (2026). China's tea trade: Current status, problems and suggestions. China Tea Processing, (03), 67–72.
[2]Wang, M., Gu, J., & Wang, H. (2023). Method for identifying tea buds based on an improved YOLOv5s model. Transactions of the Chinese Society of Agricultural Engineering, 39(12), 150–157.
[3]Liang, X. (2024). Research on identification, counting, and yield estimation of tea buds in natural environments. South China Agricultural University.
[4]Liao, S., & Zeng, J. (2025). Tea bud recognition based on YOLOv5s. Equipment Manufacturing Technology, (09), 31–34, 52.
[5]Zhang, Y. (2026). Research on recognition and localization methods for tea buds based on binocular vision. Chongqing University of Technology.
[6]Yu, K., Wang, X., & Xu, W. (2024). Design of a modular small-scale lawn-mowing robot. Modern Manufacturing Technology and Equipment, 60(02), 46–50.
[7]Qiu, X. (2025). A sound recognition and key-playing system based on STM32F407ZGT6. Shanxi Electronic Technology, (05), 1–4.
[8]Wei, X., & Tianhao, T. (2026). Electrical motors and drives (4th ed.)). China Machine Press.
[9]Zhang, H., Gu, X., & Zhang, Q. (2025). Design of a microcontroller-based automatic line-tracking and obstacle-avoidance car. Practical Electronics, 33(24), 72–76.
[10]Qi, X., Wang, J., & Yang, W. (2026). Bidirectional intelligent control method of ship steering gear based on sliding-mode active-disturbance rejection. Machine Design and Manufacturing Engineering, 55(10), 50–54.
Downloads
Published
Issue
Section
License
Copyright (c) 2027 Chensongyi Guo, Lei Lin, Bingkun Dan, Junyan Xu

This work is licensed under a Creative Commons Attribution 4.0 International License.